fig10
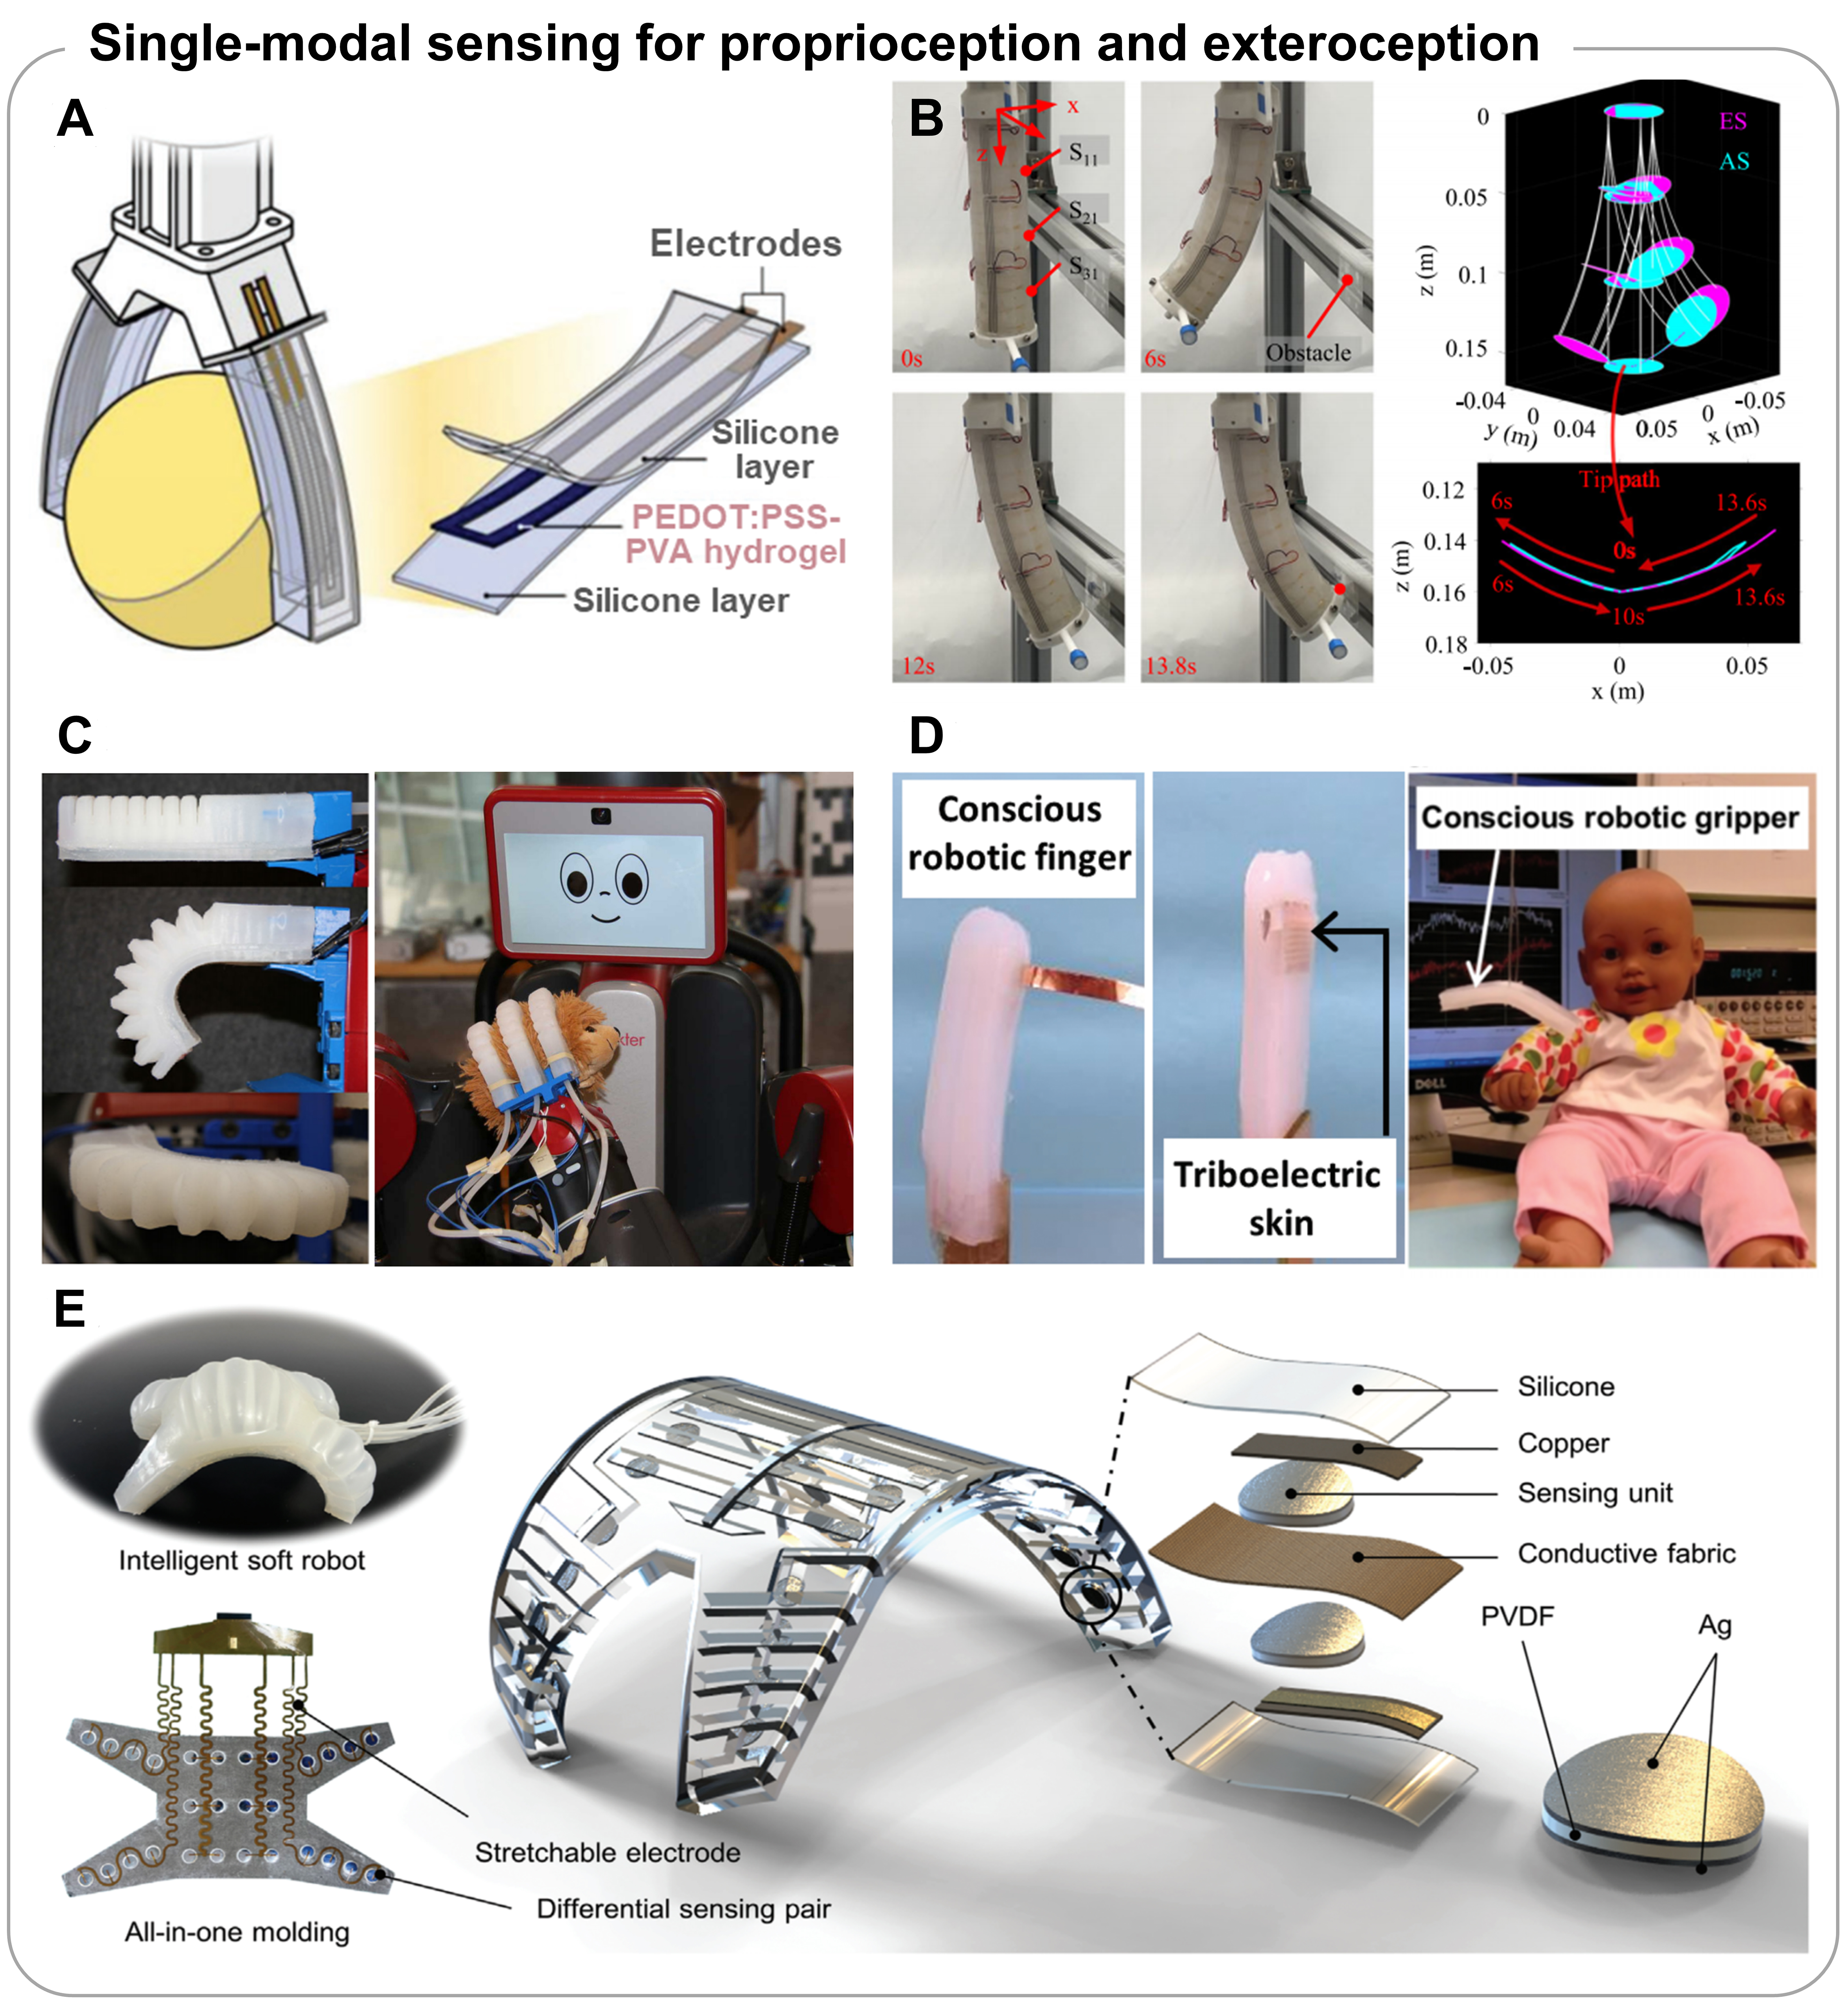
Figure 10. Representative single-modality sensing systems for integrated proprioception and exteroception in soft robots. (A) Soft gripper with integrated hydrogel strain sensor for bending monitoring. Adapted with permission from Ref.[256], Copyright © 2025 Wiley-VCH GmbH; (B) Proprioception and simultaneous contact detection during motion. Reprinted from Ref.[257], under CC BY-NC-ND 4.0 license; (C) Soft robotic hand performing object grasping. Adapted from Ref.[258], under CC BY 4.0 license; (D) Image of conscious gripper to hold the doll’s hand. Adapted with permission from Ref.[259], Copyright © 2018 Wiley-VCH GmbH; (E) Illustration of the SSES-mediated soft robot assembly. Adapted with permission from Ref.[261], Copyright © 2023 Wiley-VCH GmbH. SSES: Shape-sensing electronic skin; PEDOT:PSS: poly(3,4- ethylenedioxythiophene):poly(styrenesulfonate); PVA: poly(vinyl alcohol); PVDF: polyvinylidene fluoride.