fig9
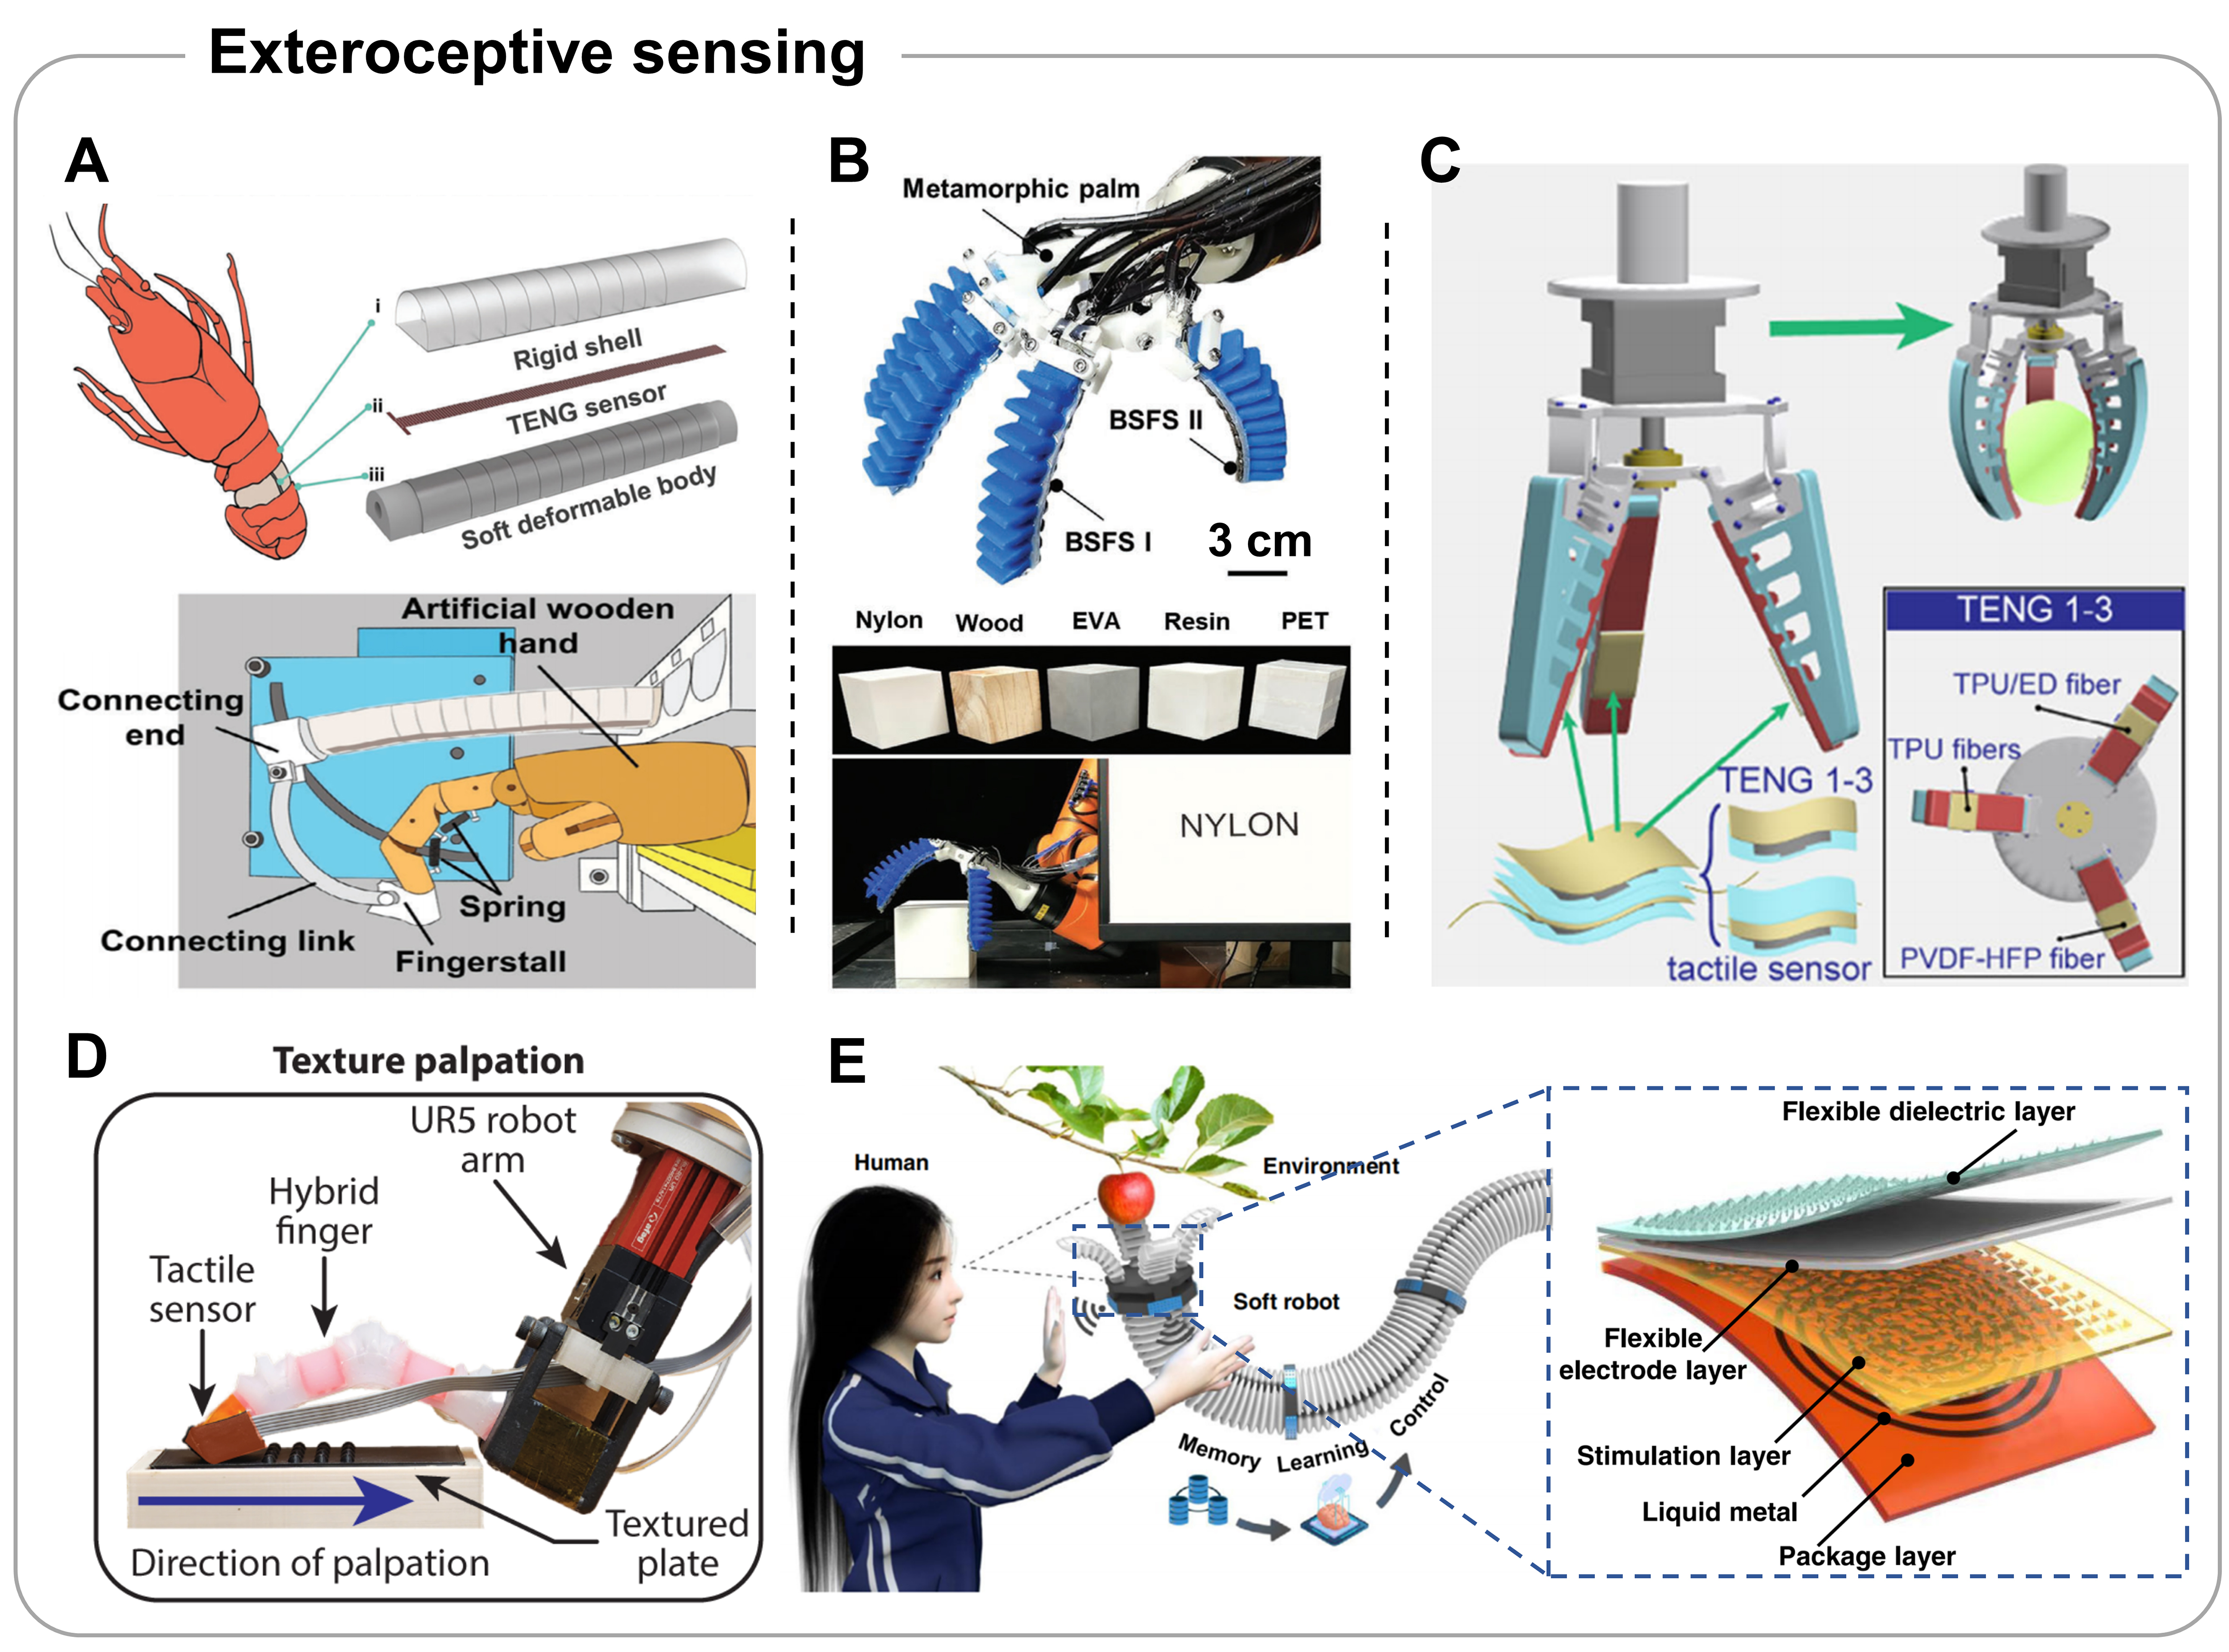
Figure 9. Representative exteroceptive sensing systems for soft robots. (A) Bioinspired TENG-SPA design and performance evaluation. Adapted with permission from Ref.[242], Copyright © 2025 Wiley-VCH GmbH; (B) The soft robotic hand identifies the material and roughness of different objects. Adapted with permission from Ref.[248], Copyright © 2023 Wiley-VCH GmbH; (C) Schematic of the mechanical gripper mounted with three sets of single-electrode TENGs and tactile sensors. Adapted with permission from Ref.[249], Copyright © 2025 Wiley-VCH GmbH; (D) Experimental setup of texture discrimination using the hybrid finger. Adapted from Ref.[250], under CC BY 4.0 license; (E) A depiction of the principle of touchless human-soft robot interaction based on flexible smart skin. Adapted from Ref.[251], under CC BY 4.0 license. TENG: Triboelectric nanogenerator; SPA: soft pneumatic actuator.